Mengze Tian

MSc student in Mechanical Engineering · EPFL

I am an MSc student in Mechanical Engineering at EPFL, where I work with Sylvain Calinon and Auke Ijspeert. I joined EPFL in 2024. My research focuses on robot learning, with interests in motion planning, manipulation, and locomotion.

Mengze Tian
I study how individual robot capabilities come together into complete embodied systems.Research perspectiveHide perspective

Research perspective

From individual robot capabilities
to complete embodied systems

My work across planning, manipulation, and locomotion has shaped how I think
about the gap between learning a skill and building a system that works.

The question connecting these experiences

How can individual capabilities come together
to complete tasks reliably in the real world?

Ongoing · Benchmark

Evaluating embodied systems

I am developing a benchmark to better understand the capabilities of embodied systems.

Looking ahead

Make behavior reliable and steerable

Build systems that combine learned skills with feedback and adaptation, and remain controllable and open to human supervision.

Research

Motion planning

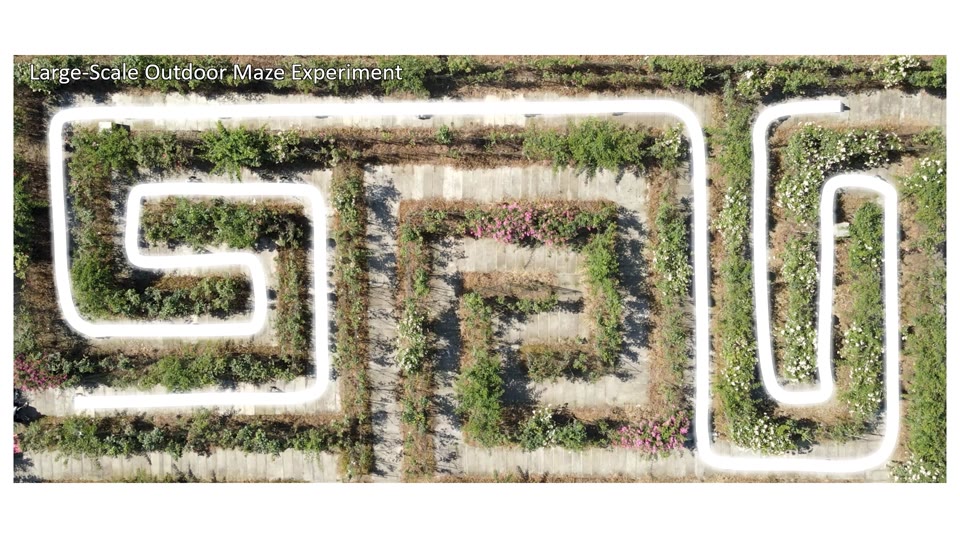
Hierarchically Depicting Vehicle Trajectory with Stability in Complex Environments

Zhichao Han†, Mengze Tian† (co-first), Fei Gao*, et al.  ·  Science Robotics, 2025

We present a hierarchical approach that integrates the spatial extraction capabilities of neural networks with the robust convergence of numerical optimization, enabling efficient and stable trajectory generation in diverse environments.

Manipulation

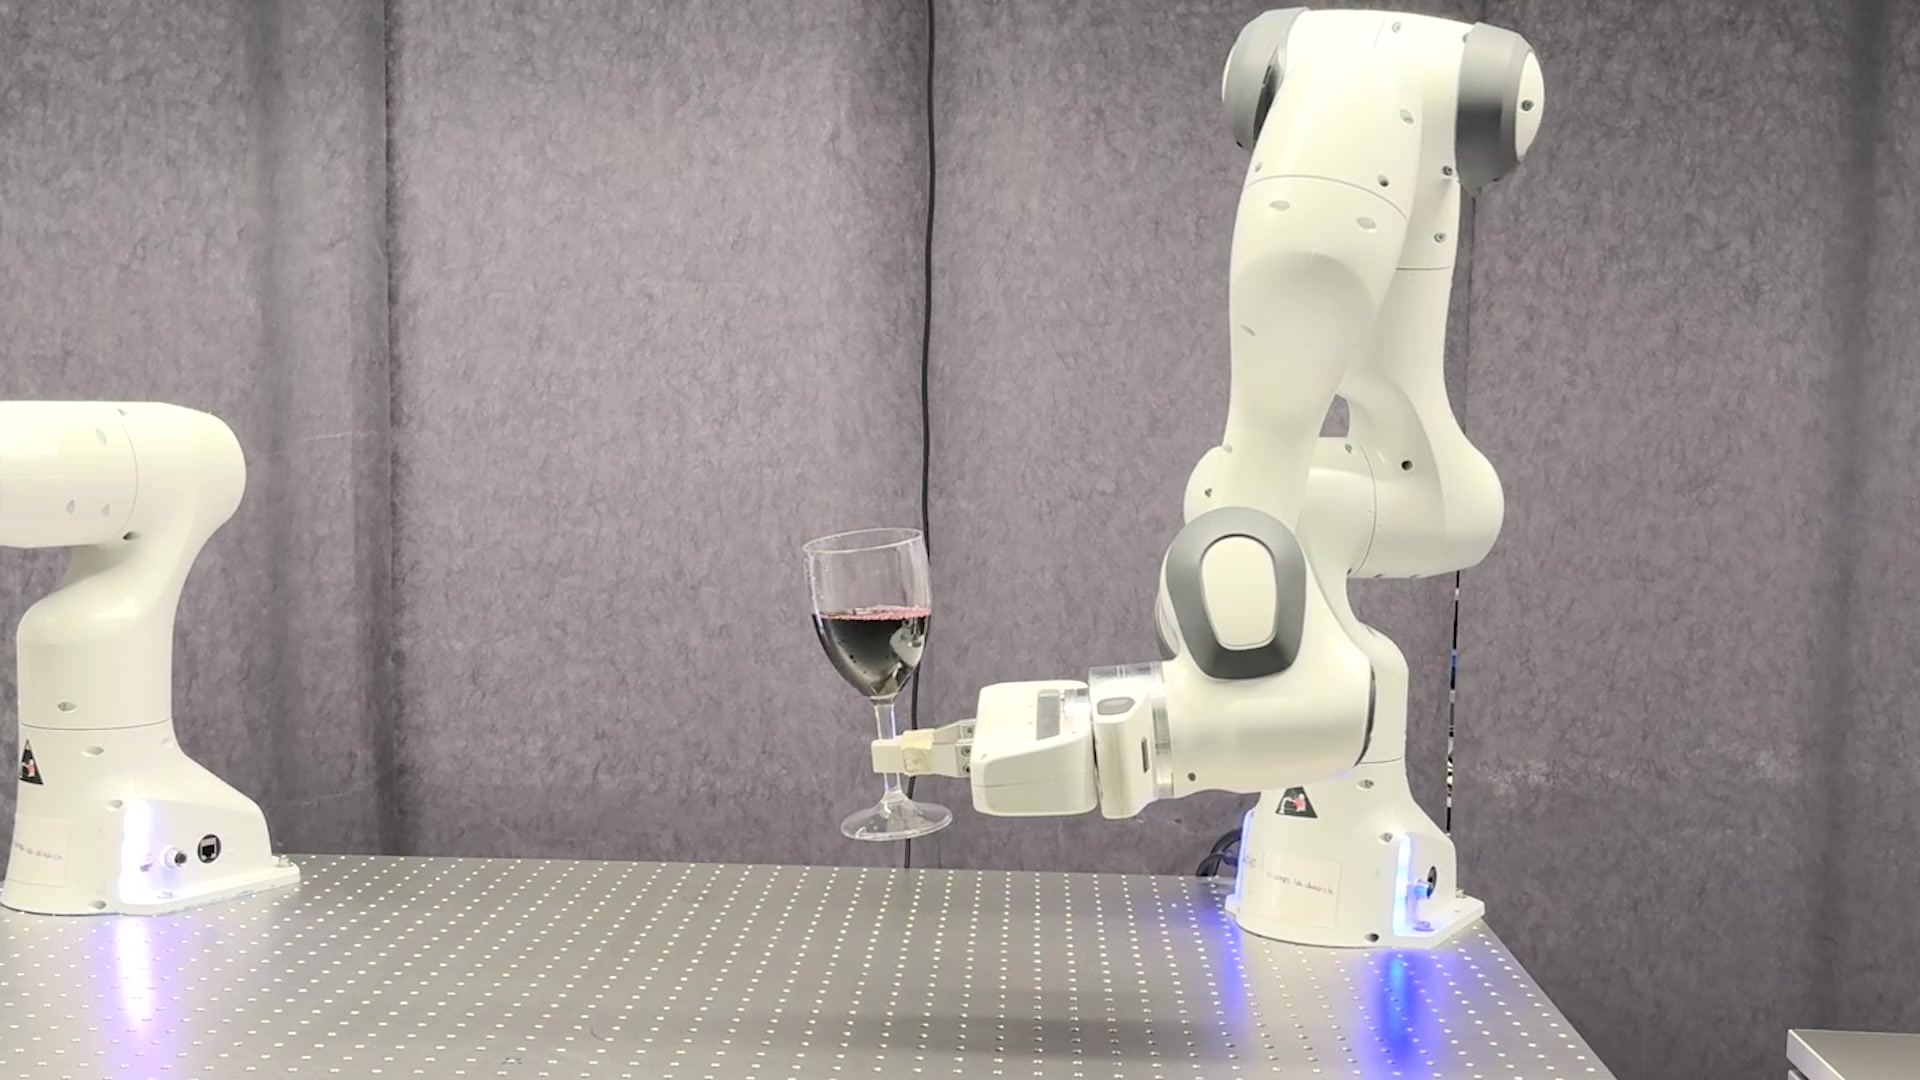
Spline Policy: A Structured Representation for Robot Policies

Mengze Tian†, Yiming Li†, Sichao Liu, Auke Ijspeert, Sylvain Calinon  ·  (under review)

We propose Spline Policy, a structured policy representation that models robot behaviors as spline trajectories rather than discrete action chunks, supporting flexible temporal evaluation, parameter-space constraints, and uncertainty propagation.

Locomotion

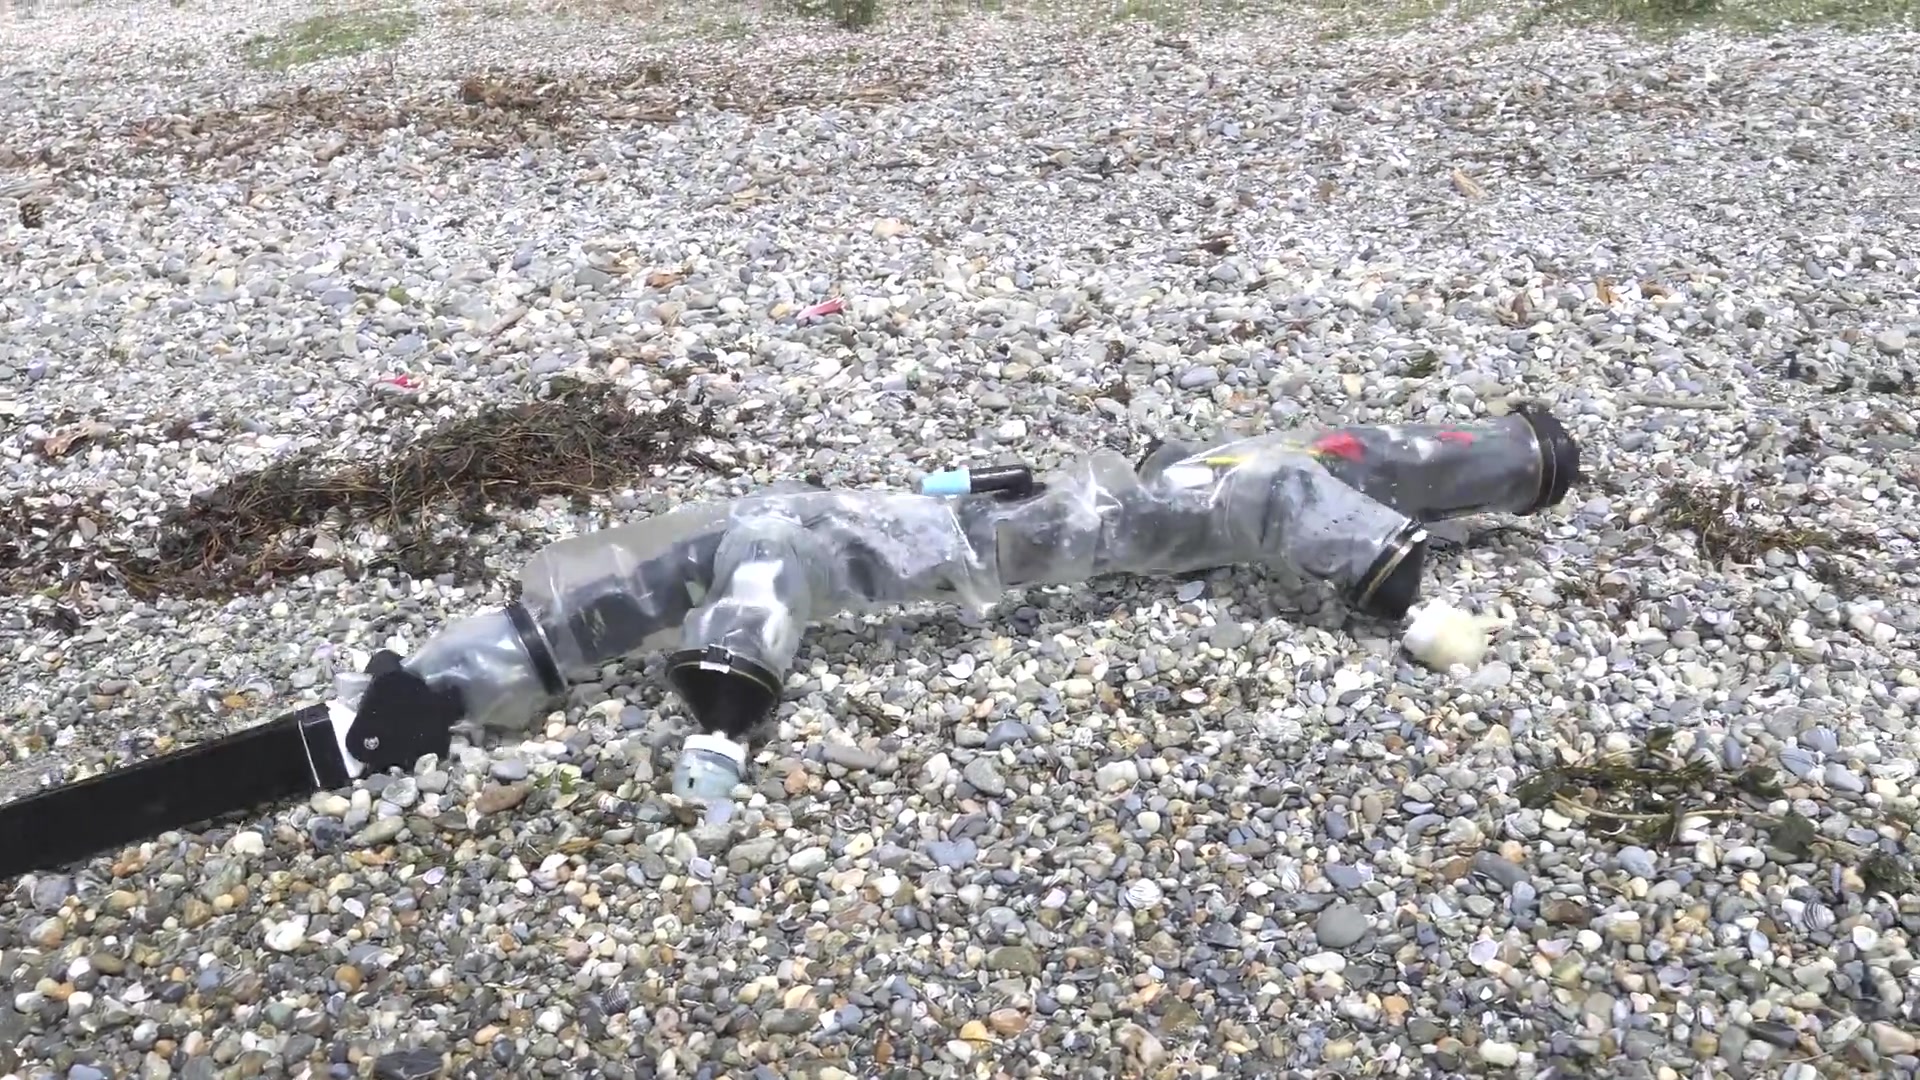
Learning Amphibious Locomotion for Salamander Robots

Mengze Tian†, Qiyuan Fu†, Chuanfang Ning, Javier Jia Jie Pey, Jonathan Arreguit, Andrea Ferrario, Auke Ijspeert  ·  (under review)

We learn a single reinforcement-learning policy for walking, swimming, and automatic transitions between them using proprioceptive feedback. A biologically inspired prior guides learning, while a system-level sim-to-real alignment pipeline accounts for sensing, actuation, mechanical backlash, and fluid interactions. We validate the policy on a physical salamander robot on flat and uneven terrain and in water.

Education & Research Experience

  1. Present

    Tsinghua University

    Research Intern

    Advisor: Yao Feng

    Benchmark.

  2. – Present

    EPFL

    MSc in Mechanical Engineering

    Advisors: Sylvain Calinon and Auke Ijspeert

    Research on structured policies for manipulation and amphibious locomotion.

  3. –

    Zhejiang University

    B.E. in Automation

    Advisor: Fei Gao

    Worked on learning-based motion planning, combining neural predictions with numerical optimization for trajectory generation.